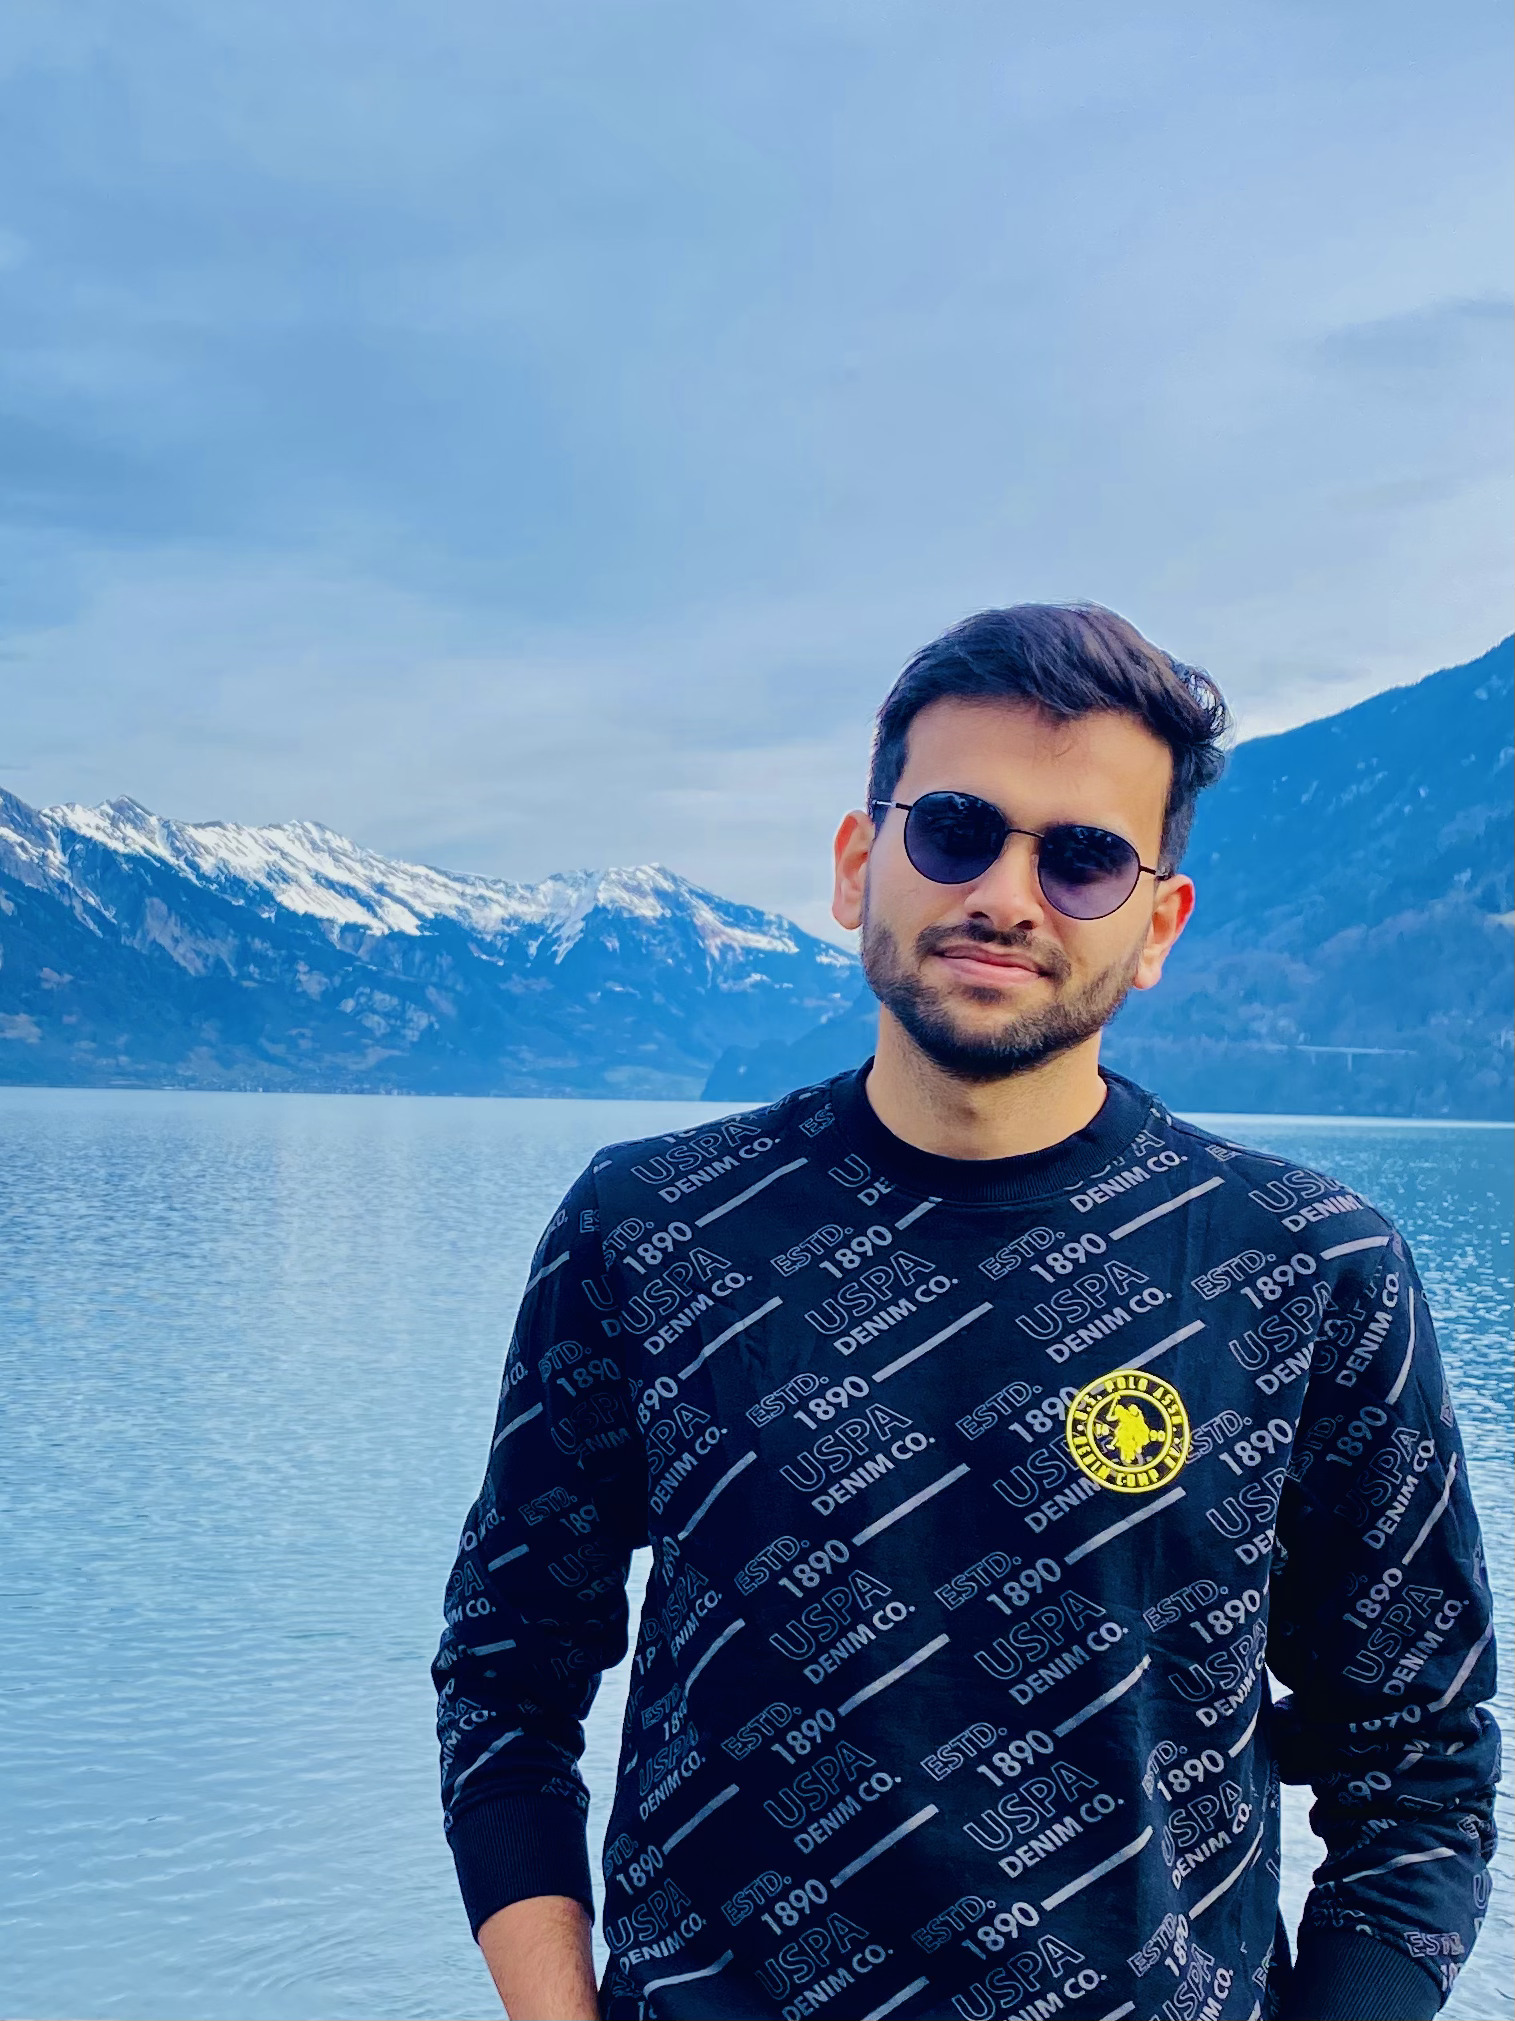
About me
👋🏼 Hi! I’m a robotics software engineer working on 3D perception and real-time autonomy for physical vehicles and robots. I build and deploy multi-sensor pipelines (stereo, RGB-D, LiDAR) for pose estimation, 3D geometry, and sensor fusion under real-time constraints on embedded Linux (NVIDIA Jetson), using C++ and Python with ROS 2. My work spans camera/sensor calibration, perception-to-control integration, and taking systems from prototype to reliable operation on real hardware.
I completed my MSc in Computational Science & Engineering (Robotics & Computer Vision) at ETH Zürich, where I also worked as a Research Assistant at the SCAI Lab on assistive robotics and multi-view 3D reconstruction. Before that, I studied at IIT Roorkee and spent two years in R&D at Sterlite Technologies building simulation models for industrial processes.
I’m currently open to robotics / perception engineering roles and available to start immediately. Here’s my CV.
Recent work: ArtiTwinSplat (interactable digital twins with Gaussian Splatting, ICRA 2026 workshop) and ROS 4 Healthcare (Frontiers in Robotics and AI). See all projects.
News
- 08/2026 - Finished my MSc at ETH Zürich and my Research Assistant role at SCAI Lab.
- 06/2026 - Presented ArtiTwinSplat (lightning talk & poster) at the ICRA 2026 Digital Twins workshop in Vienna.
- 2026 - ROS 4 Healthcare published in Frontiers in Robotics and AI.
- 01/2026 - Started building a multi-camera 3D human pose & body model pipeline (SCAI Lab × AIT Lab).
- 08/2024 - Joined the SCAI Lab (D-HEST, ETH Zürich) as a Research Assistant.
- 09/2023 - Started my MSc at ETH Zürich!